Minwoo Jung
Robust Perception and Mobile Robotics Lab. / Seoul National University

I am a Ph.D. candidate in Mechanical Engineering at Seoul National University (SNU), advised by Prof. Ayoung Kim in the Robust Perception and Mobile Robotics Lab. My research focuses on LiDAR SLAM, sensor fusion, and place recognition for robust robot localization across heterogeneous sensors and long-term environments.
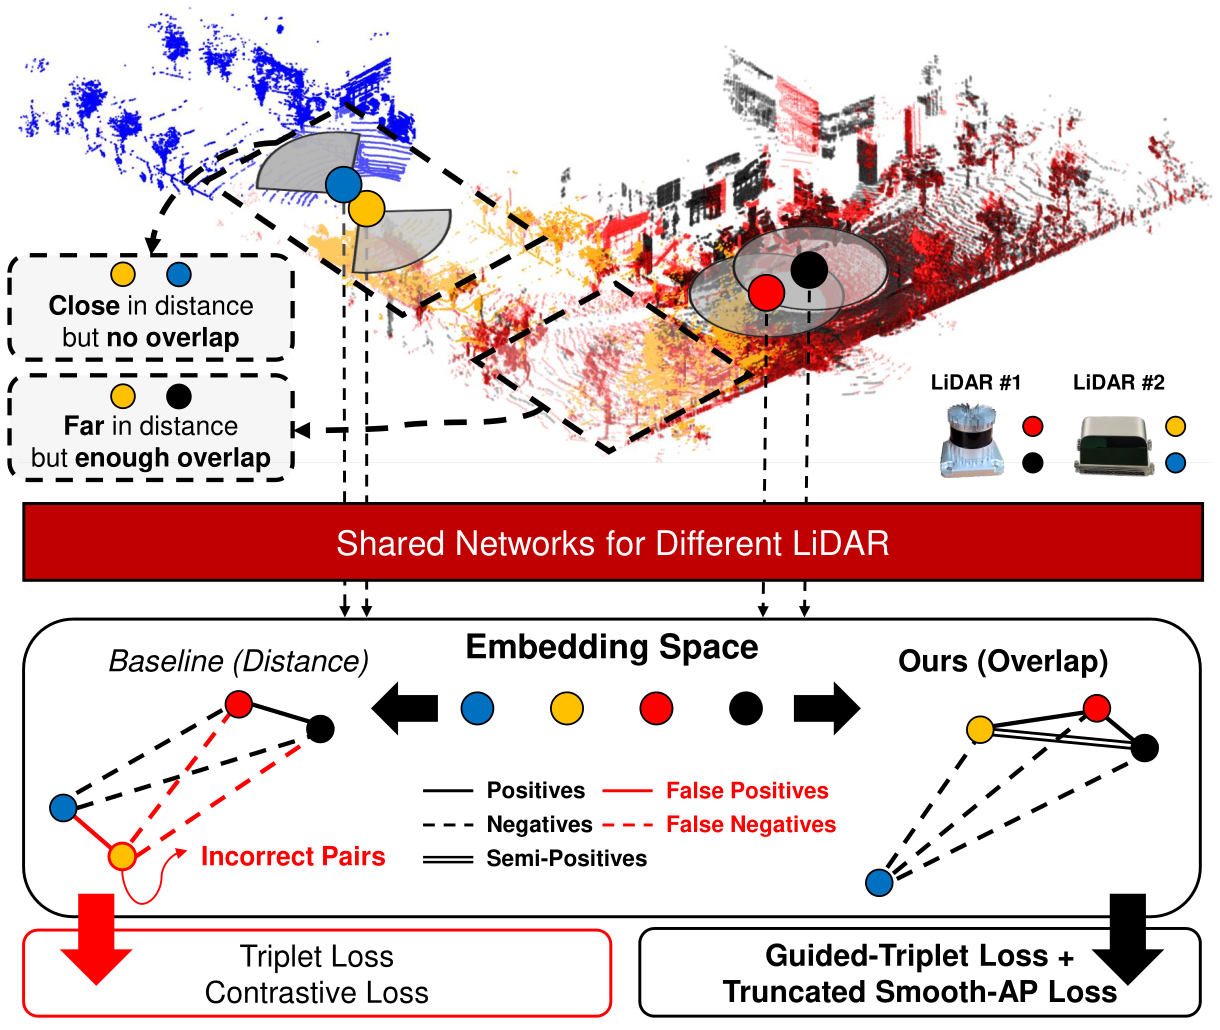
Before starting my Ph.D., I received my M.S. in Mechanical Engineering from SNU and my B.S. in Civil and Environmental Engineering from KAIST. During my graduate studies, I have worked on multiple LiDAR-inertial odometry, heterogeneous LiDAR place recognition, radar-LiDAR localization, and large-scale datasets for autonomous navigation.
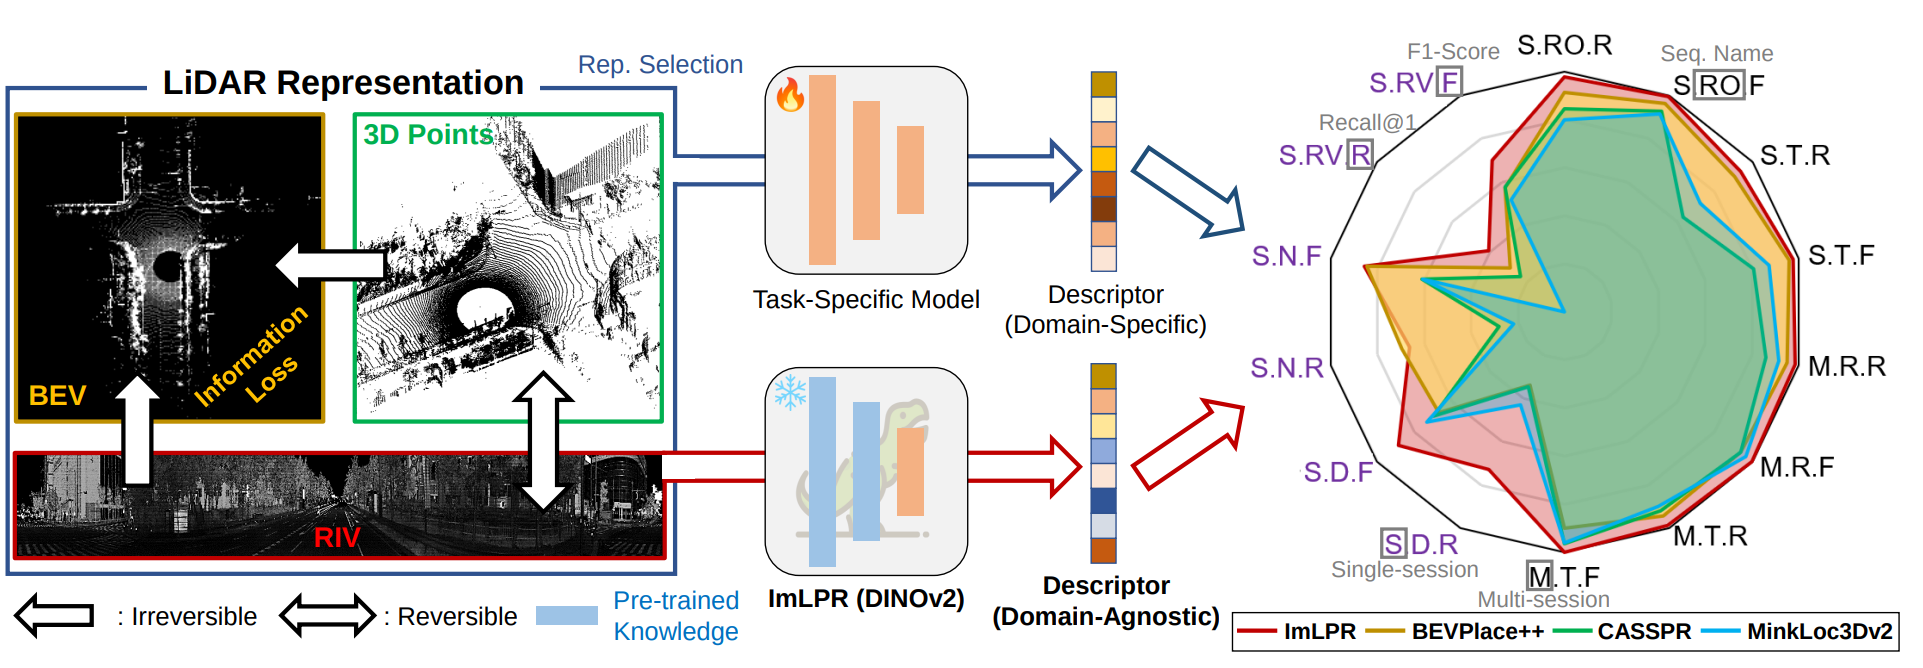
I was a visiting research student with the Oxford Robotics Institute DRS Group in 2025, where I collaborated on LiDAR place recognition with vision foundation models and geometric localization in forest environments.
news
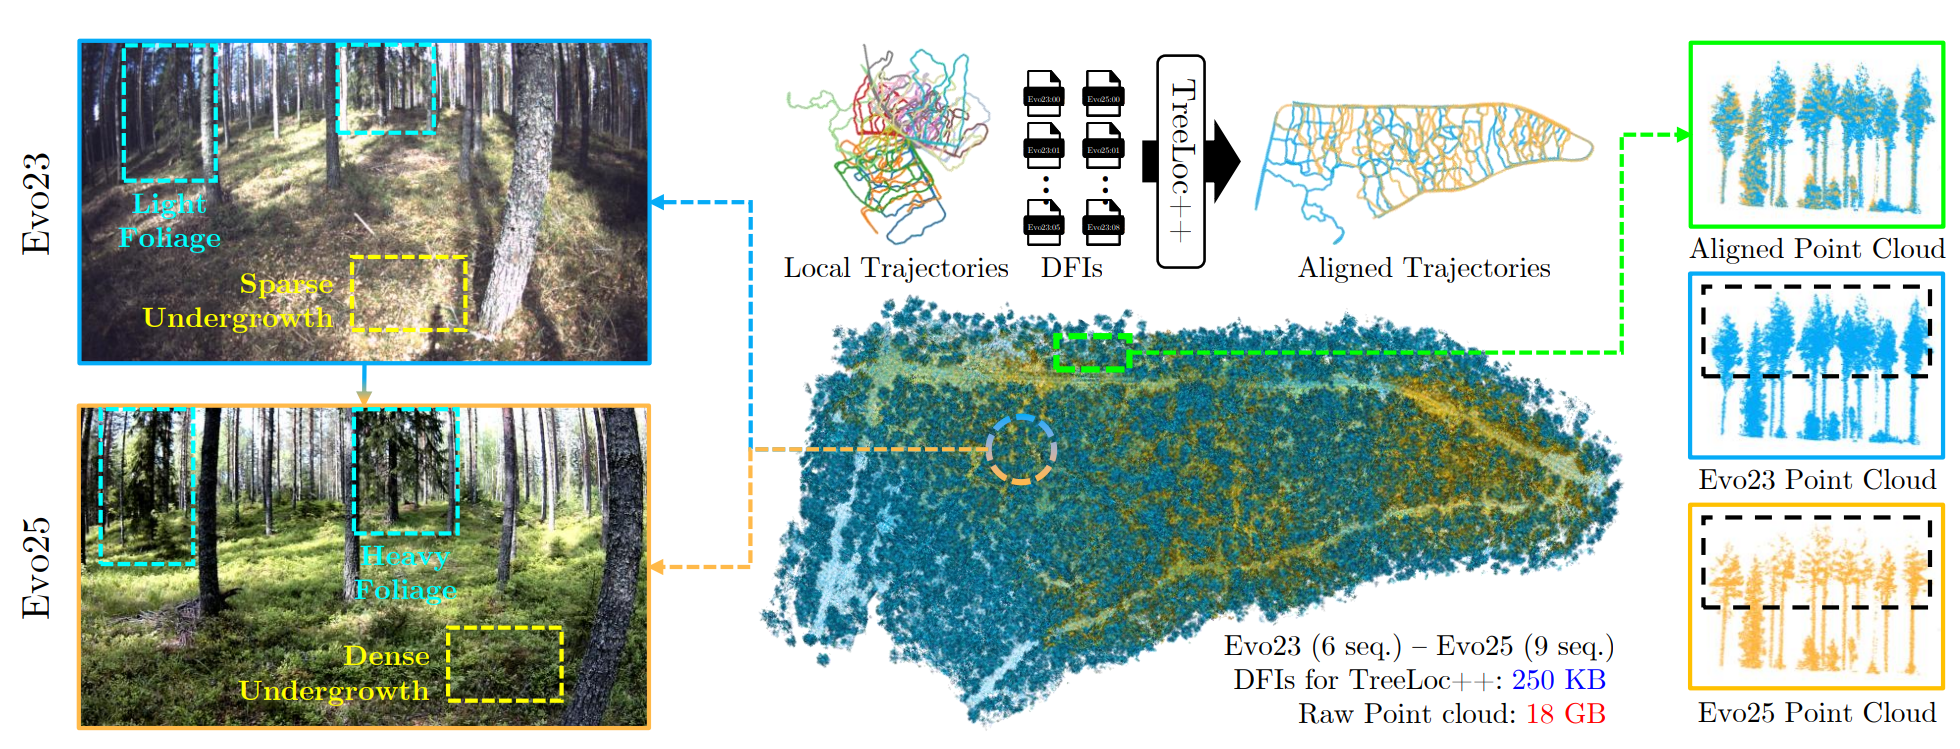
| Oct 2026 | Gave an invited talk on TreeLoc++ in the Physical AI session at the International Symposium on AI Convergence and Applications (AICA) 2026 in Jeju, Korea. |
|---|---|
| Aug 2026 | Attended the Korean Conference on Computer Vision (KCCV) 2026 at BEXCO, Busan, Korea. |
| Aug 2026 | ELite++ was accepted to the International Conference on Control, Automation and Systems (ICCAS) 2026 (corresponding author). |
| Aug 2026 | Are Visual Place Recognition Models Recognizing Places or Conditions? is available as an arXiv preprint (2nd author). |
| Jul 2026 | Attended the International Conference on Machine Learning (ICML) 2026 in Seoul, Korea. |
| Jul 2026 | Attended the Institute of Control, Robotics and Systems (ICROS) Annual Conference 2026 in Daegu, Korea. |
| Jul 2026 | TreeLoc++ was accepted to IEEE Transactions on Field Robotics (T-FR) (1st author). |
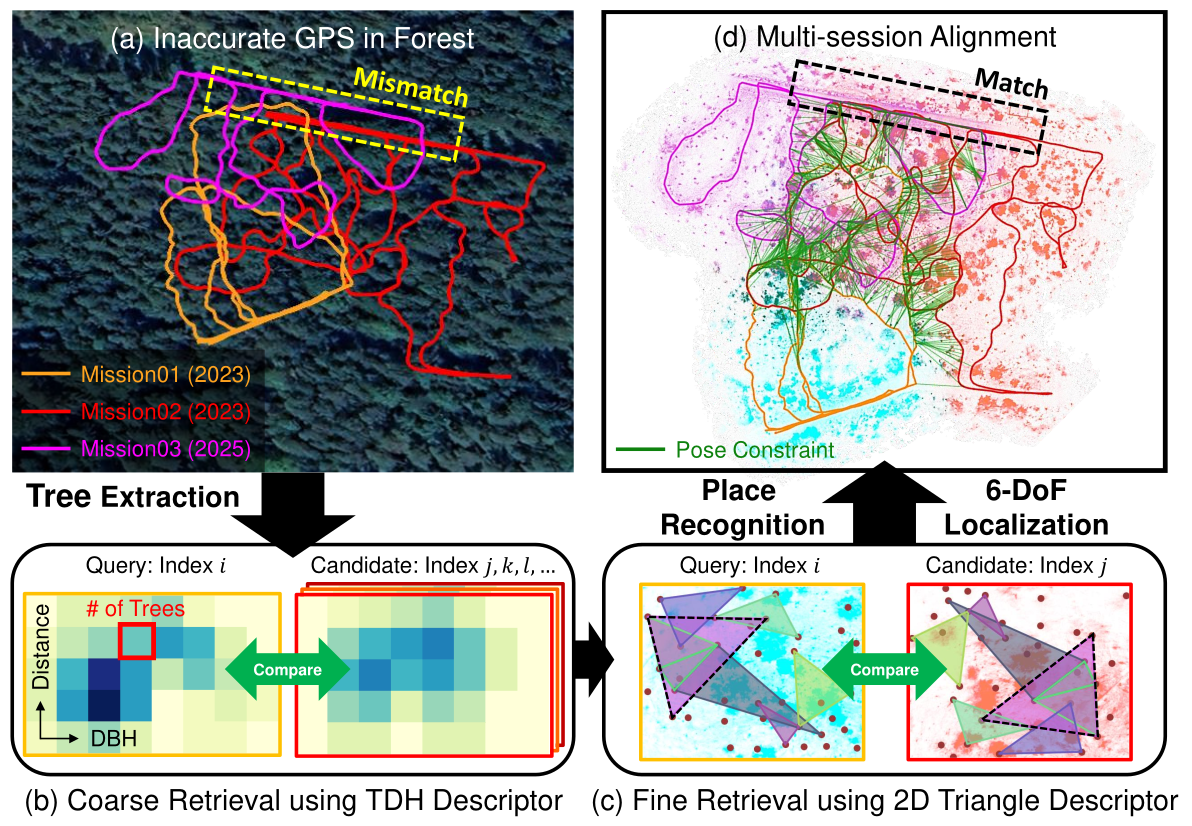
| May 2026 | Will present TreeLoc at the IEEE International Conference on Robotics and Automation (ICRA) 2026 in Vienna, Austria. |